Kinematic Reachability Field Studies
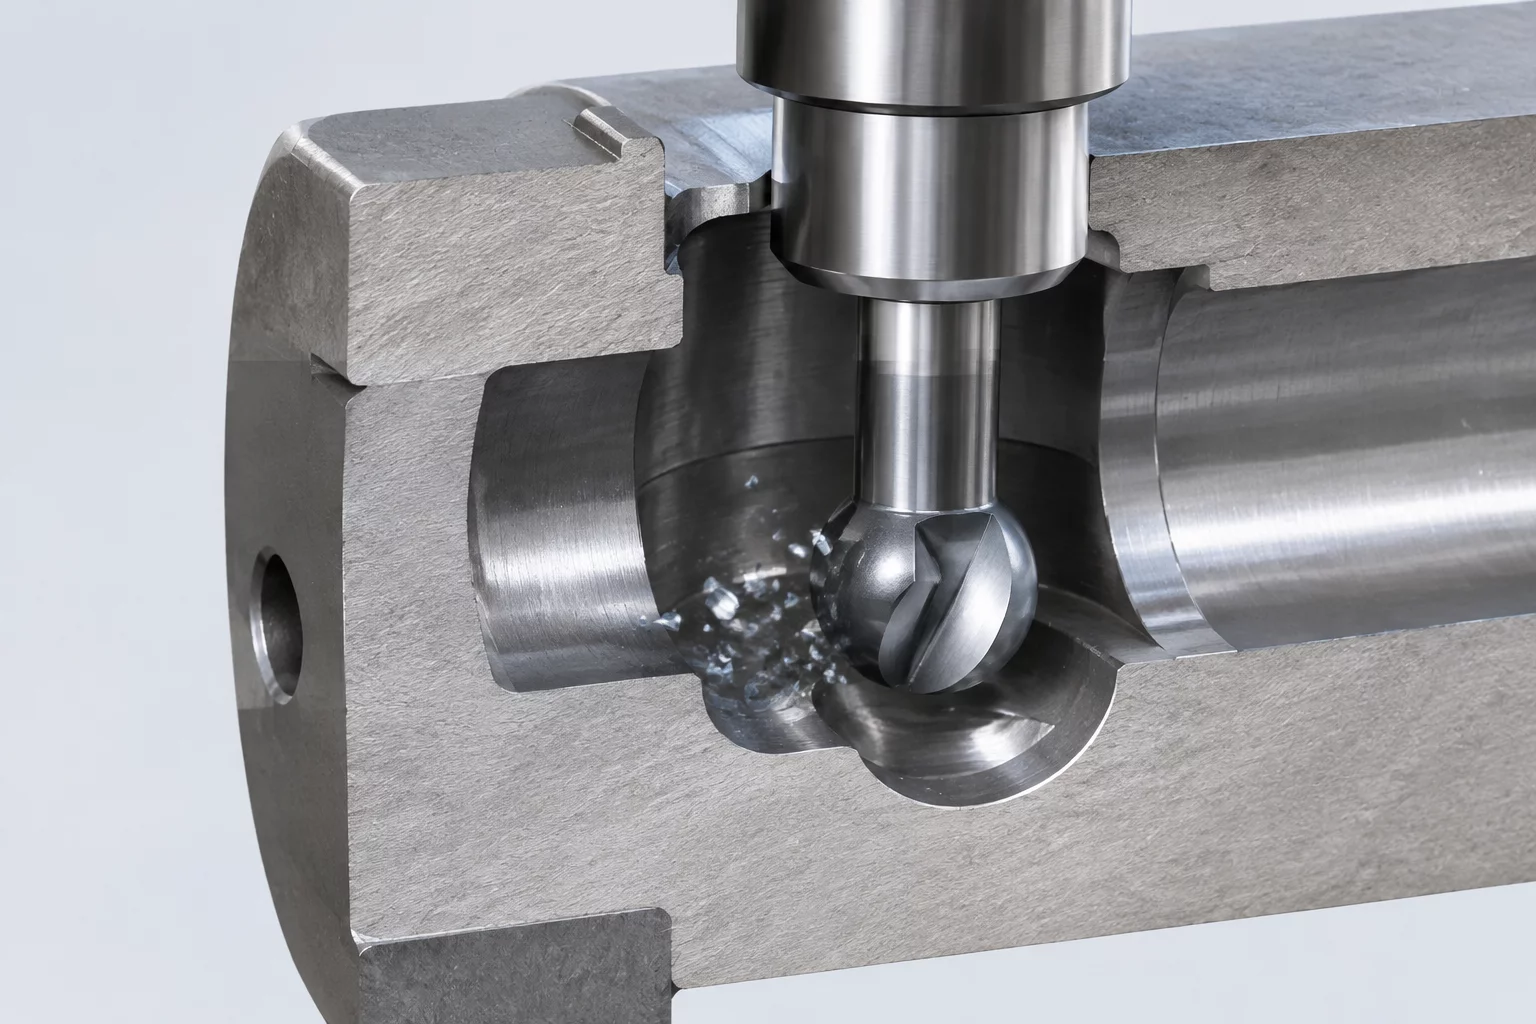
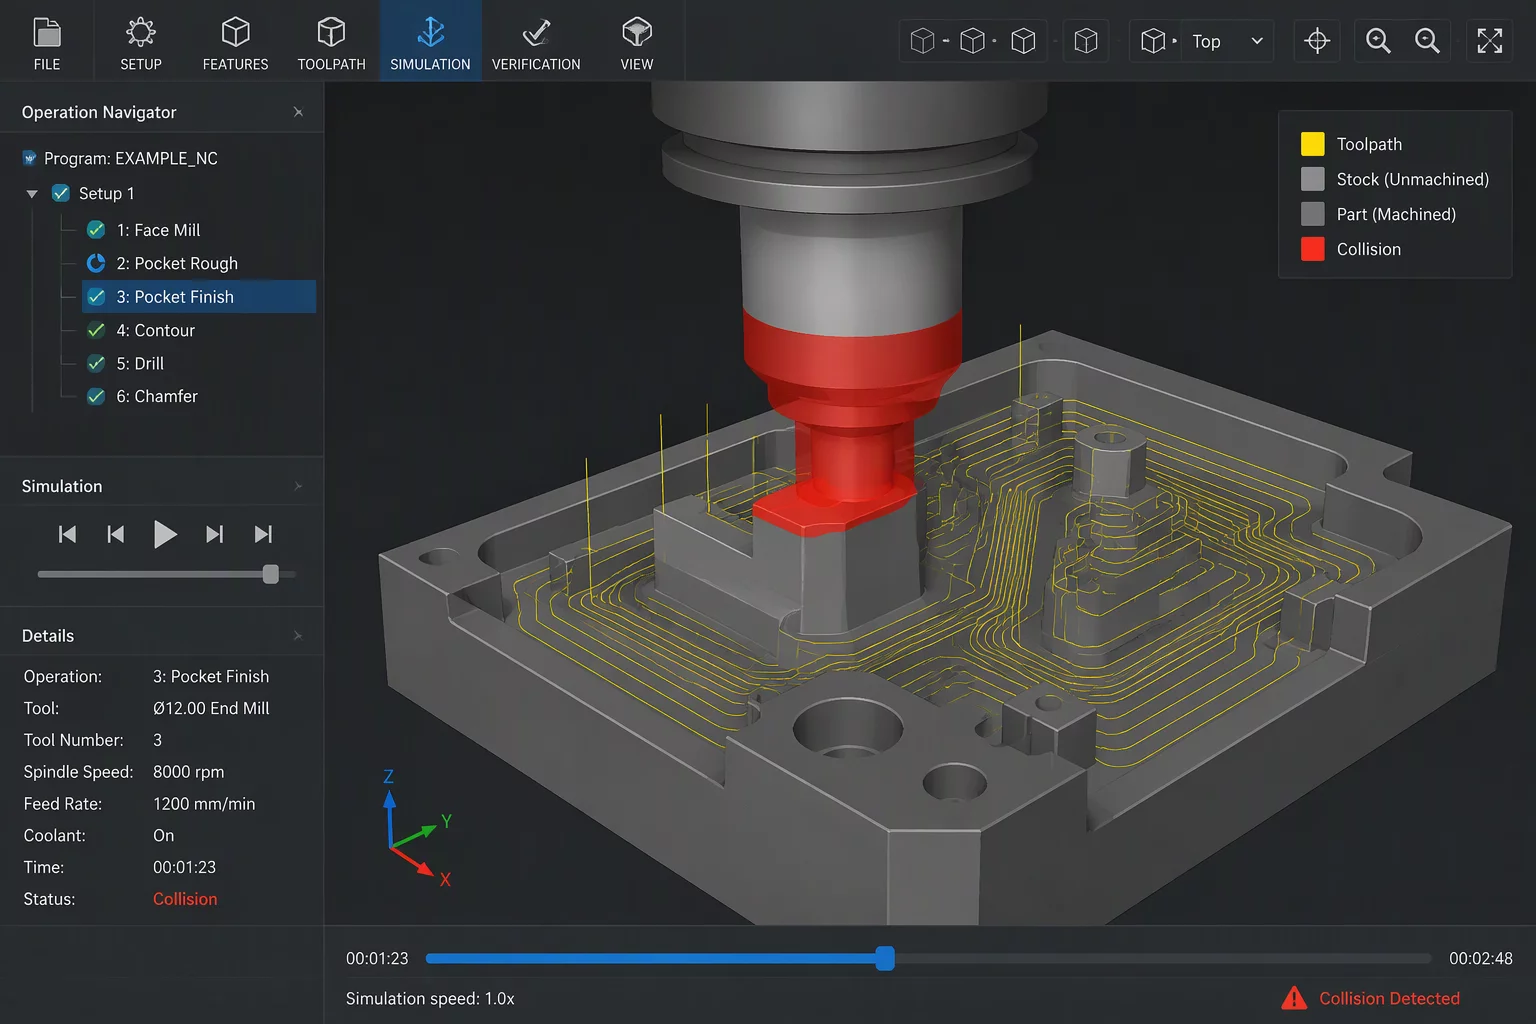
Systematic technical evaluation of tool holder envelopes, tight pocket approach trajectories, and 5-axis tilt coordination to guarantee zero gouging and maximum cutter rigidity.
Feature Access
2026-10-14
•
Michael Brown
Analyzing physical access constraints across deep recesses and steep sidewalls to determine optimal cutter overhang and machine reach.
Read Case Analysis
Feature Access
2026-09-30
•
David Smith
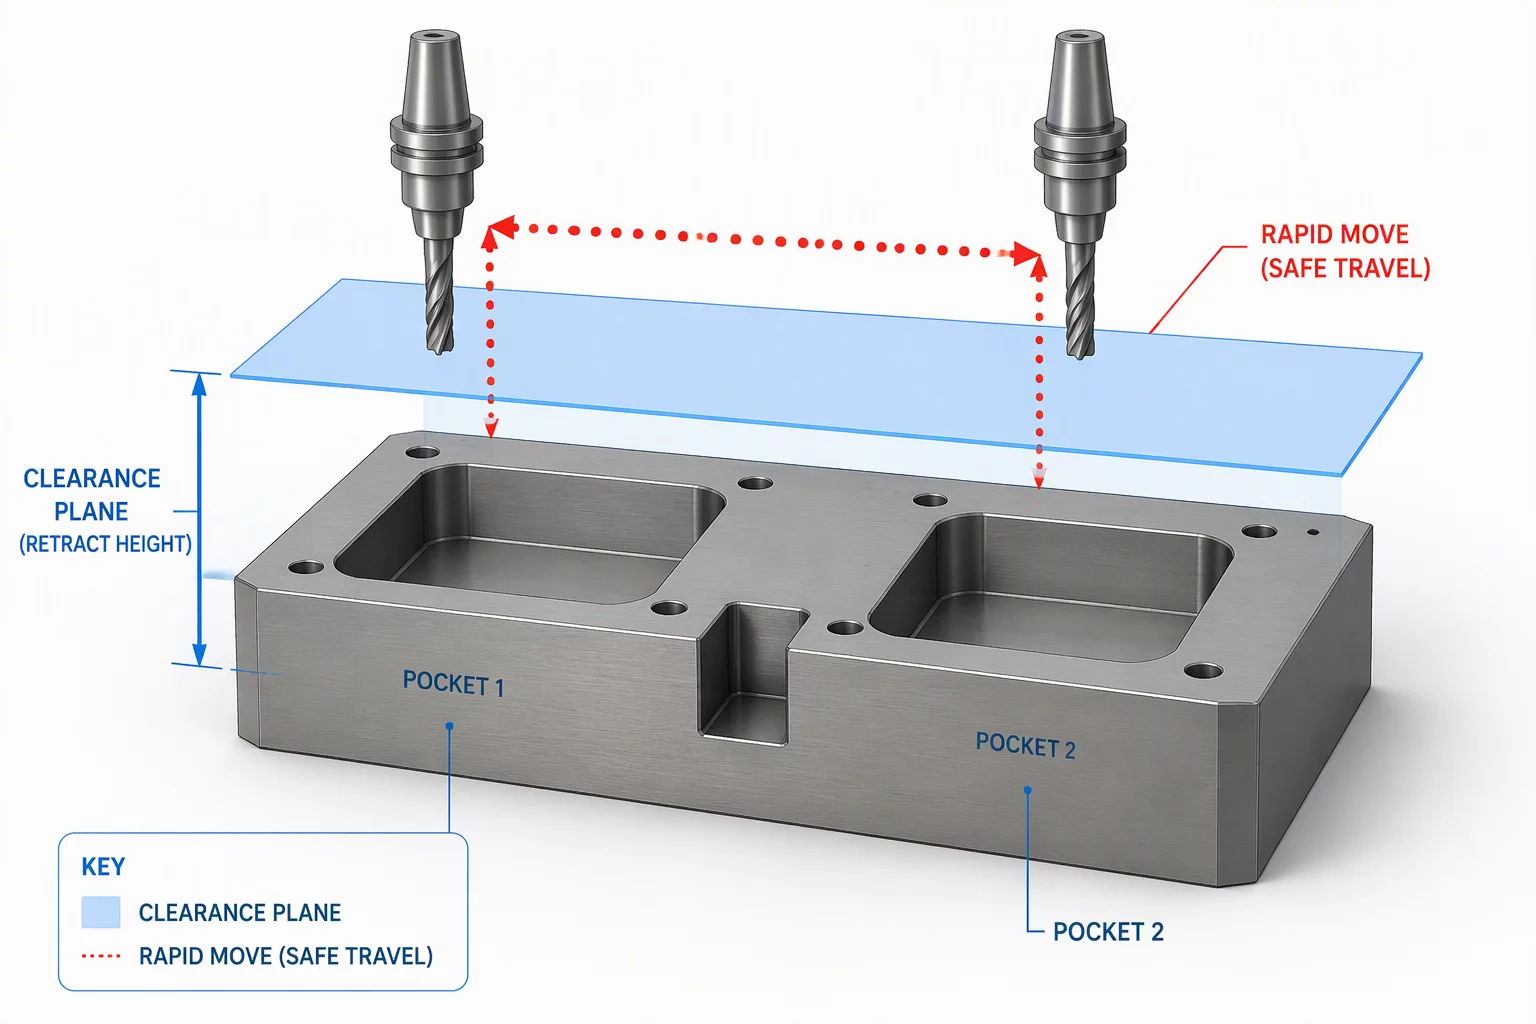
Planning safe clearance planes and dynamic approach heights to eliminate non-cutting rapid traverse collisions in complex envelopes.
Read Case Analysis
Feature Access
2026-09-18
•
Laura Davis
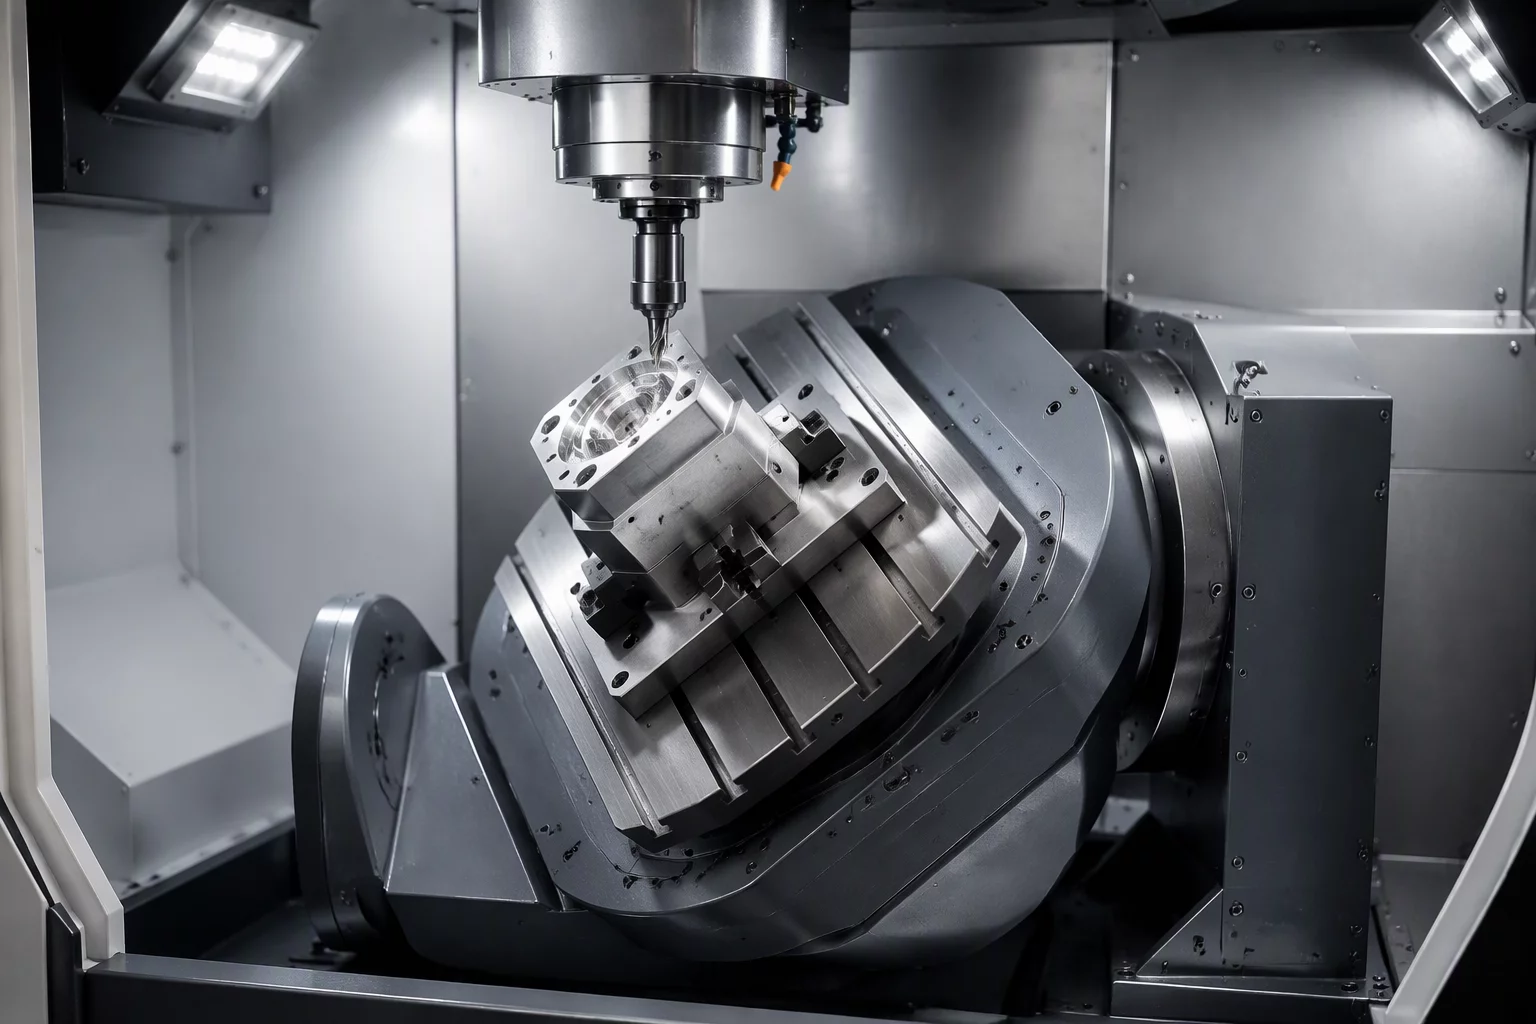
Angle planning and continuous tool axis vector steering for multi-axis pocket clearing and undercut contoured walls.
Read Case Analysis
Feature Access
2026-09-05
•
James Miller
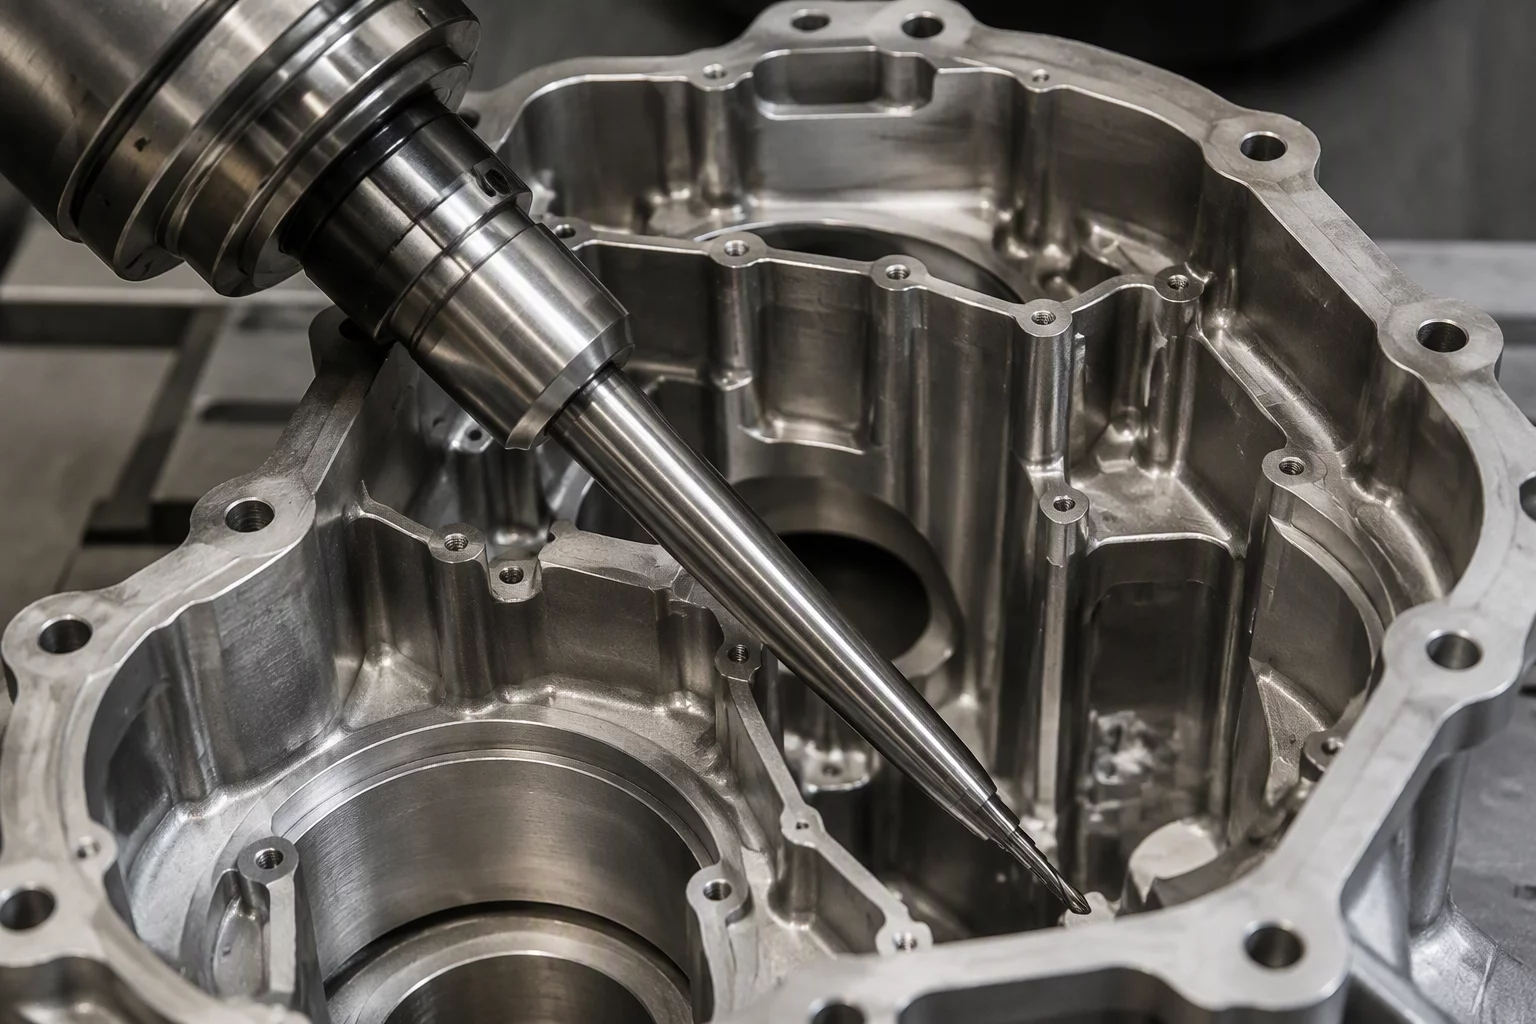
Reaching tight, confined internal pockets using specialized tapered shank tooling without compromising structural cutter rigidity.
Read Case Analysis
Feature Access
2026-08-28
•
Sarah Jenkins
Checking and simulating full 3D tool holder bodies against evolving stock models and fixture clamps to prevent spindle gouges.
Read Case Analysis
Feature Access
2026-09-20
•
James Miller
Material removal is not feature completion. Verifying that a toolpath actually completes the intended feature.
Read Case Analysis
Feature Access
2026-09-05
•
James Miller
A tool can physically reach a surface yet fail to achieve the machining intent in multi-axis machining.
Read Case Analysis
No matching operations found
Reset the filter above to display all technical sequence studies.